A camera guides our robot arm to pick things up
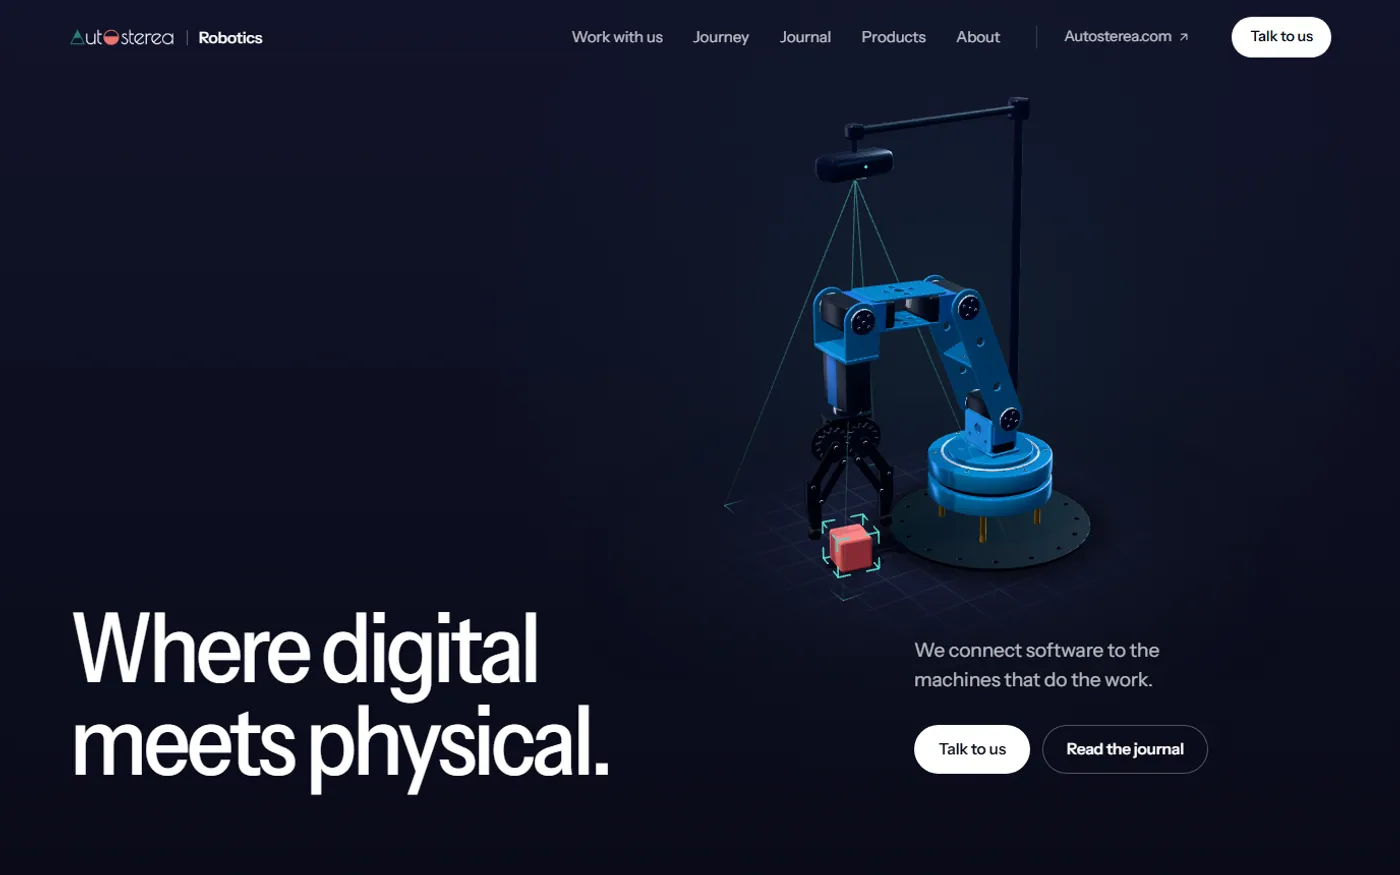
Our robotics lab: a camera watches the table and guides a robot arm to pick up and move objects.
Why robotics
Manufacturers have work that people do by hand, again and again. We are building the robotics to take it on.
Our first project is a robot arm that a camera guides.
What we built
- Camera guidanceA camera looks down at the table, finds each object and tells the arm where to reach.
- A taught camera mapWe taught the camera where the arm is. Its map is good to about 2.6 mm.
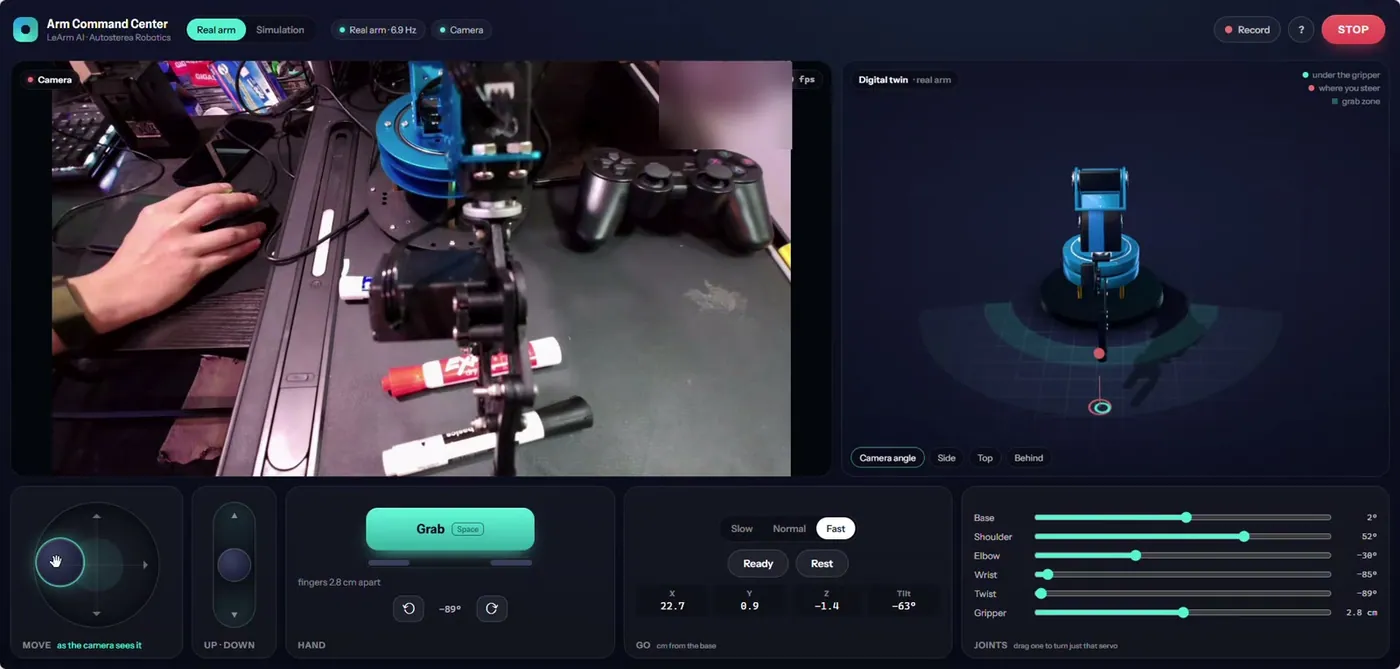
- Command centerOne screen to drive the real arm, with the live camera and a 3D twin that follows each move.
- The websiterobotics.autosterea.com shows the work, a public journal and the road ahead.
How it works
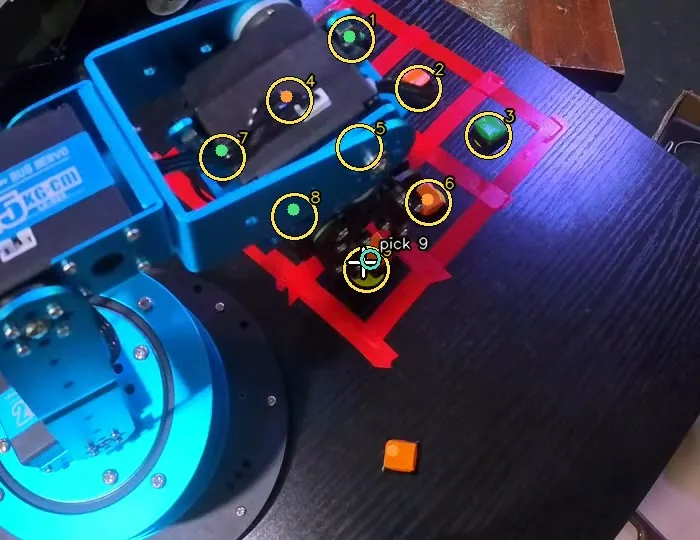
- The camera reads the board and the object on each spot.
- The software works out where the arm must reach.
- The arm lowers, grips and lifts.
- It carries the object to its new spot and lets go.
What changed
On October 26, 2026, the arm passed 5 of 5 place-and-pick tests. The next day it cleared the row nearest to it on its own, 6 cubes out of 6.
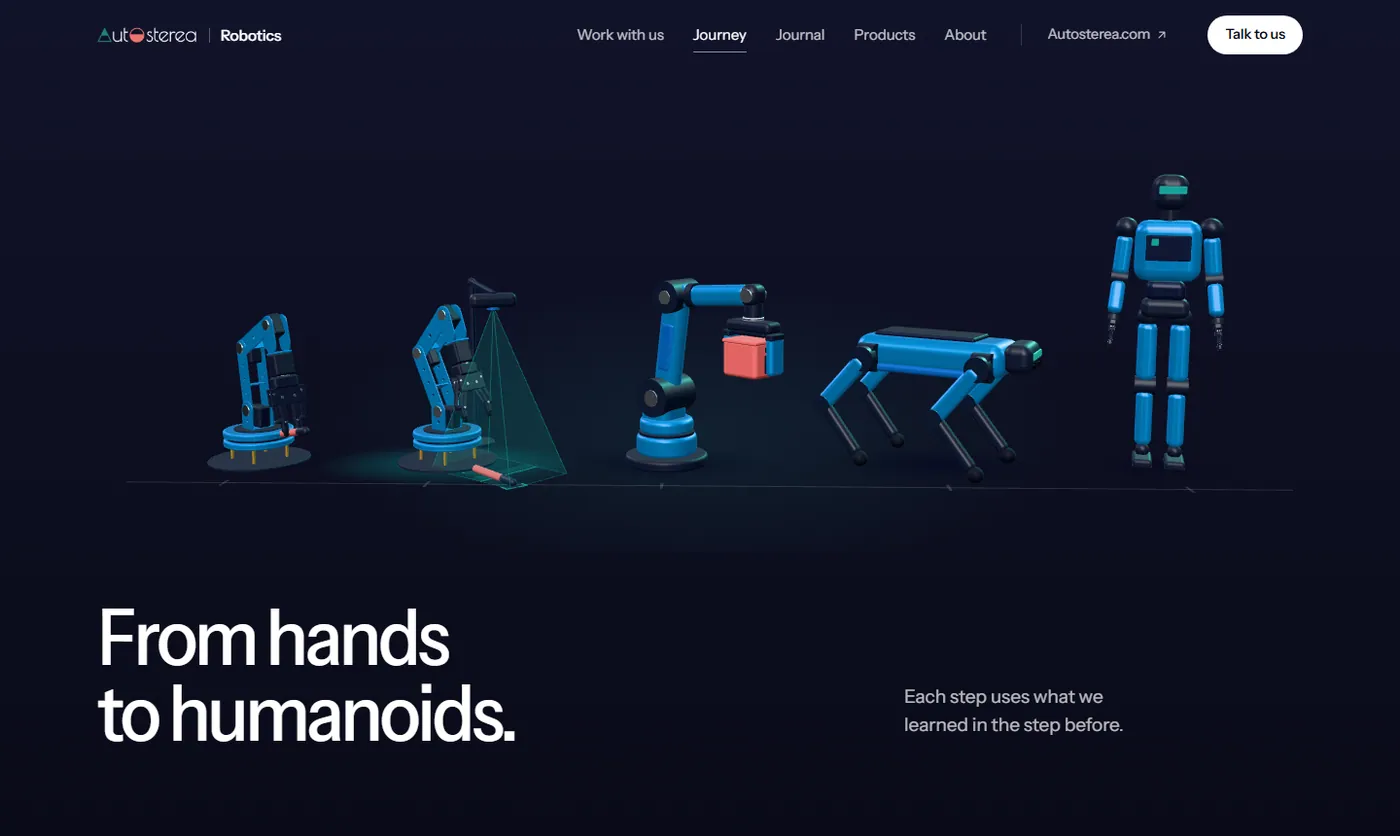
Next come bigger hands, then robots with four legs and with two.
Built with
- Python
- OpenCV
- Next.js
- Three.js
- Claude